Feagine Robotics is pushing the boundaries of robotics with its innovative approach to cross-embodiment intelligence. By developing Fi0, a foundation model that retains task knowledge across robots with different physical structures, they're tackling a fundamental challenge in robotics: the need for intelligence that can adapt to changing hardware.
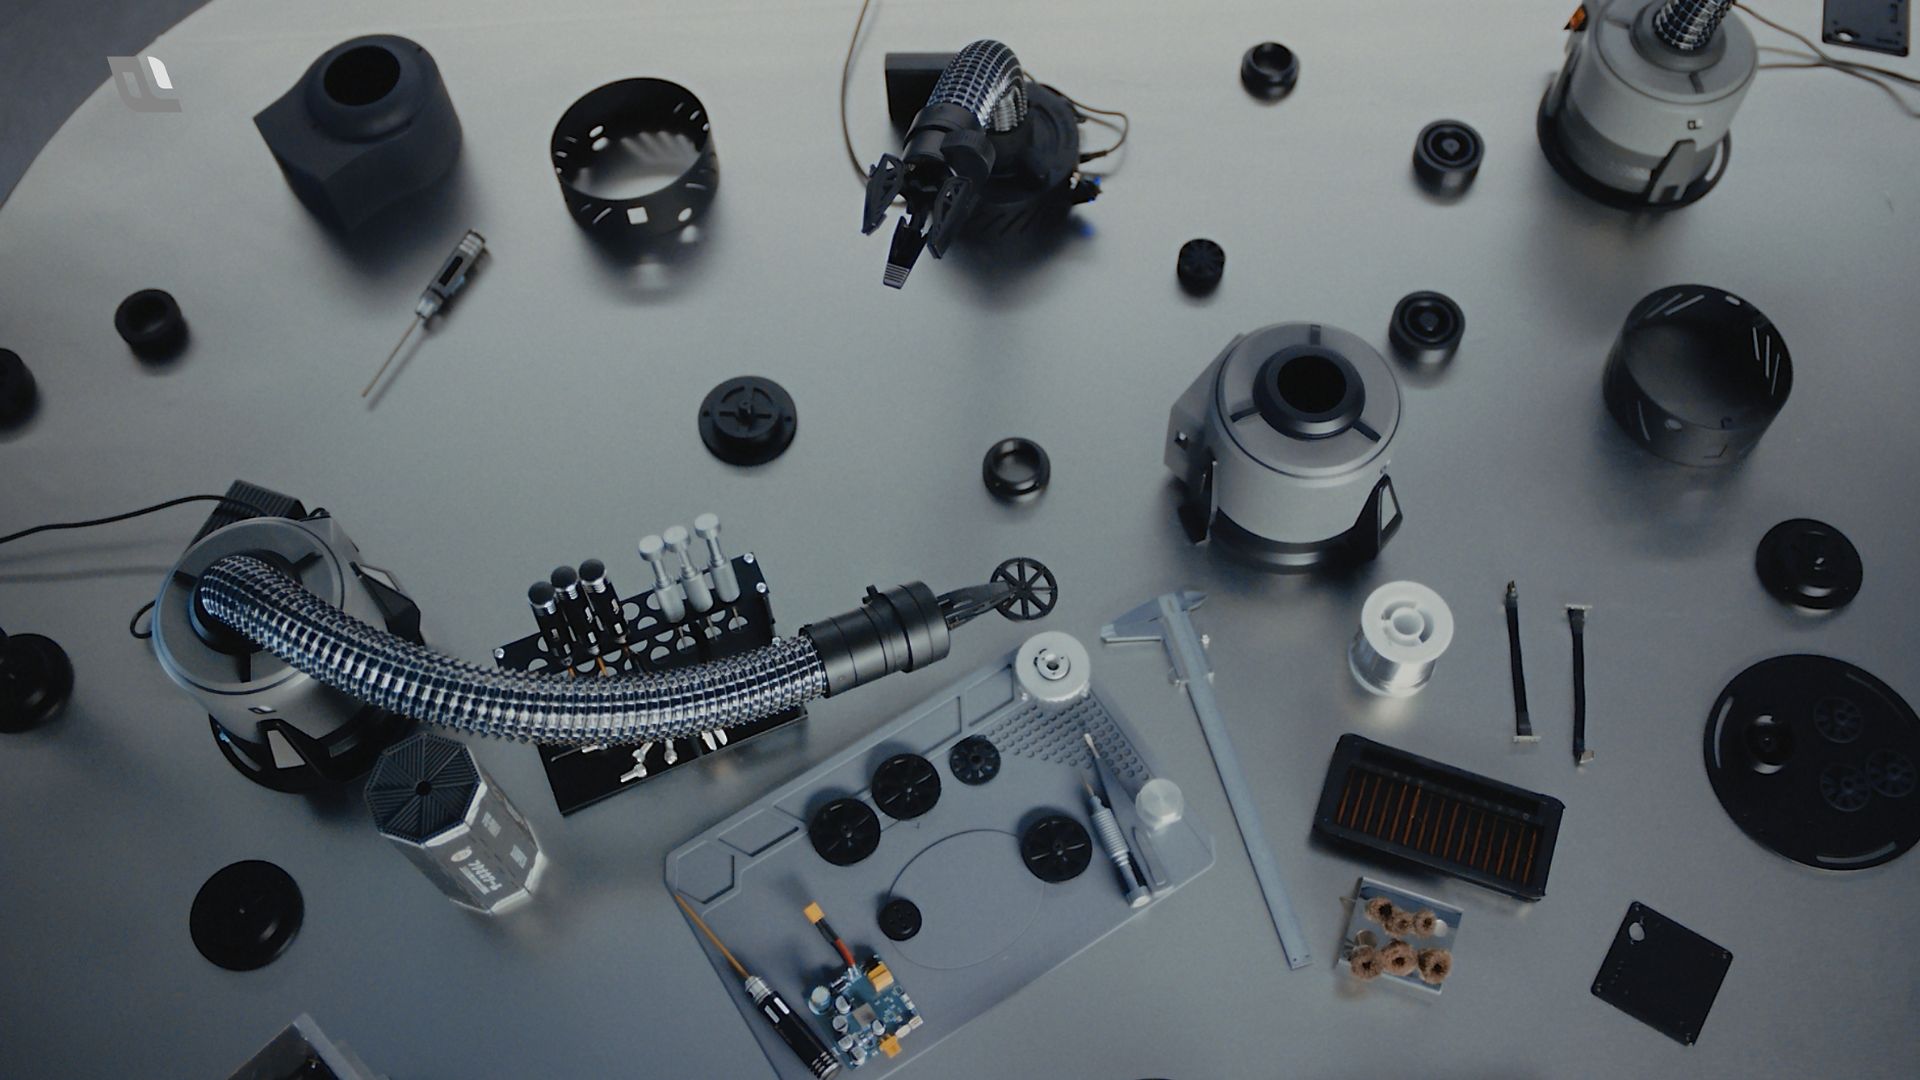
The company's three tendon-driven soft manipulators, A01, A02, and A03, are designed to showcase the potential of cross-embodiment learning. These manipulators have varying lengths, segment counts, and degrees of freedom, highlighting the importance of considering a robot's physical structure when developing AI. Soft robots, with their ability to bend continuously and change shape, present a unique challenge and opportunity for AI systems.
Fi0's architecture incorporates an Embodiment Graph, which represents the robot's morphology, sensing, actuation, and current state. This approach allows the model to understand the physical configuration of the robot and adapt its actions accordingly. By treating the robot's body as part of the problem, Feagine is enabling intelligence that can move between different specialized bodies.
One of the key advantages of this approach is the reduced need for retraining when robots encounter unfamiliar tasks. With Fi0, a single demonstration from a human can provide the necessary context for the model to adapt and learn. This is particularly interesting in the context of soft robots, where the physical configuration plays a significant role in the AI's understanding.
Feagine's work challenges the notion that general-purpose intelligence requires a humanoid body. Instead, they're exploring the idea that one intelligence can operate many specialized bodies. This concept has broader implications for the future of robotics, suggesting that a growing family of specialized machines could share an increasingly capable intelligence layer.
While Fi0 is still an early-generation system, the potential for cross-embodiment intelligence to revolutionize robotics is significant. By addressing the bottleneck of embodied AI, Feagine's approach could lead to a more adaptable and versatile future for robotics, where intelligence is not tied to a single universal robot but can be shared across a diverse range of specialized machines.